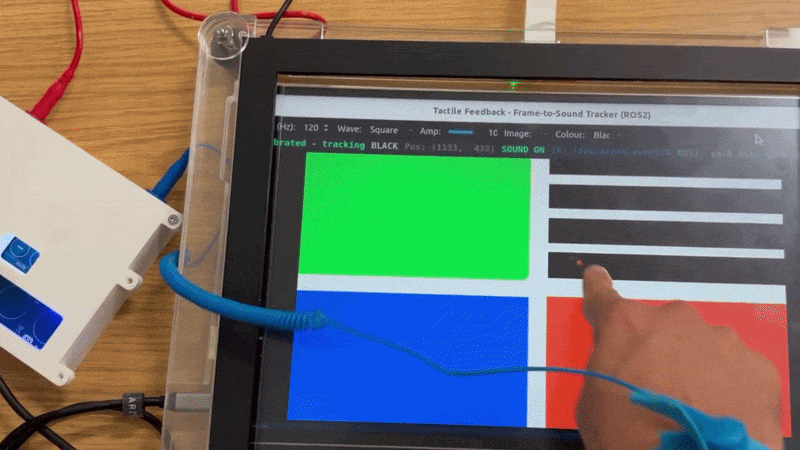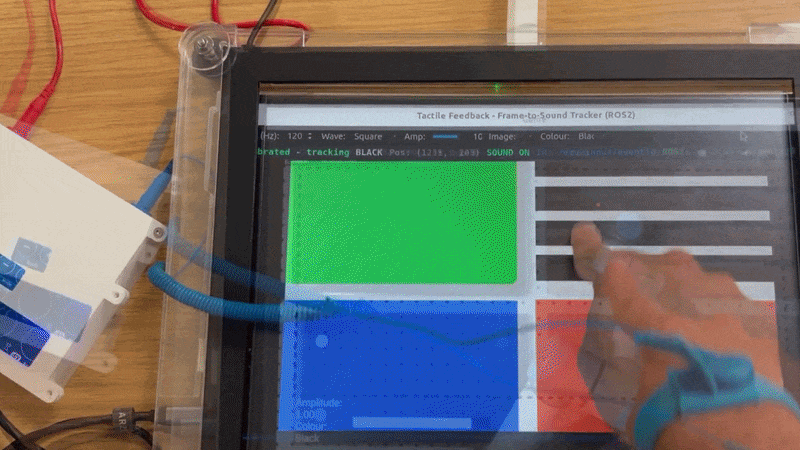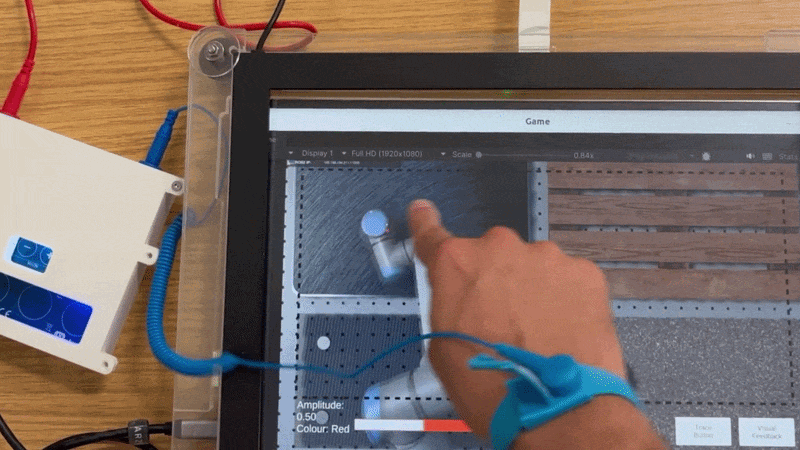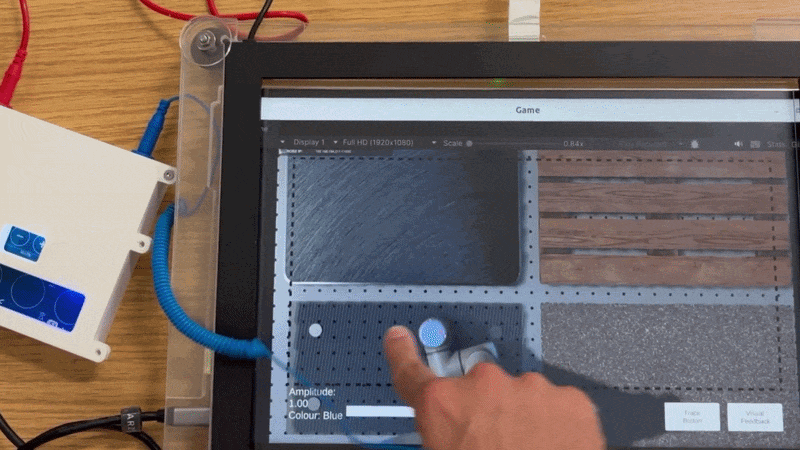
👆 Tactile Teleoperation
Electrovibration-based tactile feedback for touchscreen robot teleoperation. Designing interfaces that let operators perceive remote contact through a touchscreen, with applications in hazardous and nuclear environments.
Based in Bristol, UK · Bristol Robotics Laboratory
I work at the intersection of Robotics, Human-Robot Interaction, Teleoperation, Haptics, Digital Twins, Robot Learning and Control to design interfaces that connect people, robots and complex environments.
Research driven by the following principles: design with people in mind, validate on real systems and environments, and make advanced robotics useful.
I am a Robotics Engineer and a final year PhD Candidate working on human-robot interaction. My doctoral research at the Bristol Robotics Laboratory focuses on teleoperation interfaces for hazardous nuclear environments, including touchscreen electrovibration feedback, remote manipulation and multi-operator, multi-robot systems.
Alongside teleoperation, I investigate how robots can learn motion from human demonstrations and how generated behaviour can be evaluated for human-likeness.
My preferred research cycle is:
Analyse Requirements → Design → Build → Test with people → Validate on real systems.
Selected projects from my work in teleoperation, tactile interfaces, robot learning and nuclear robotics.
Electrovibration-based tactile feedback for touchscreen robot teleoperation. Designing interfaces that let operators perceive remote contact through a touchscreen, with applications in hazardous and nuclear environments.
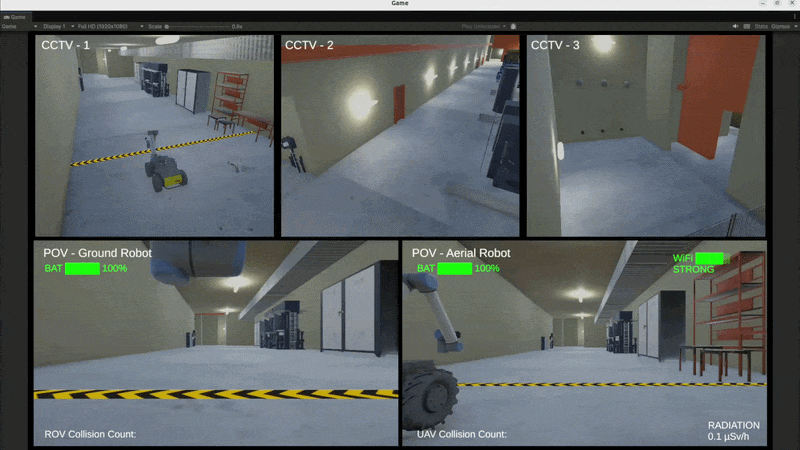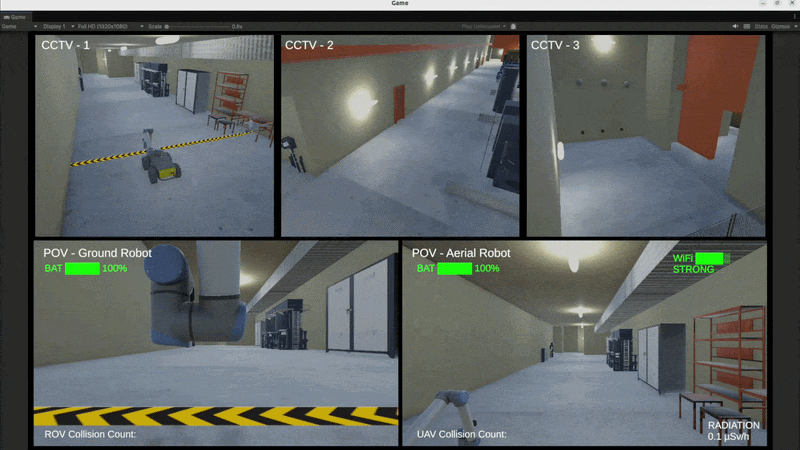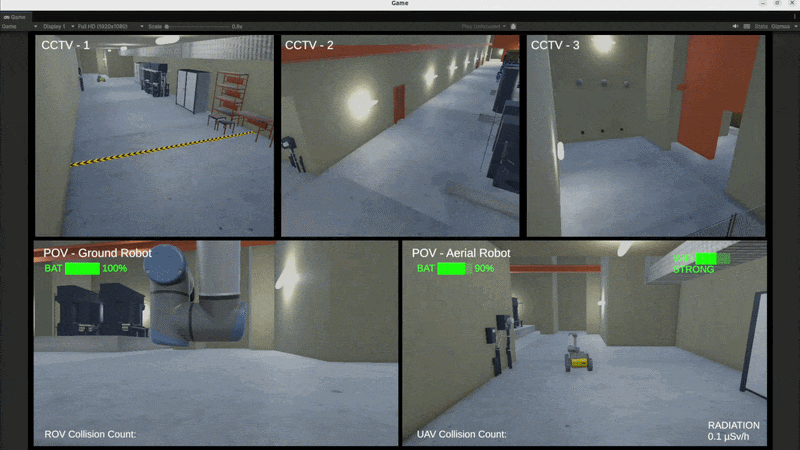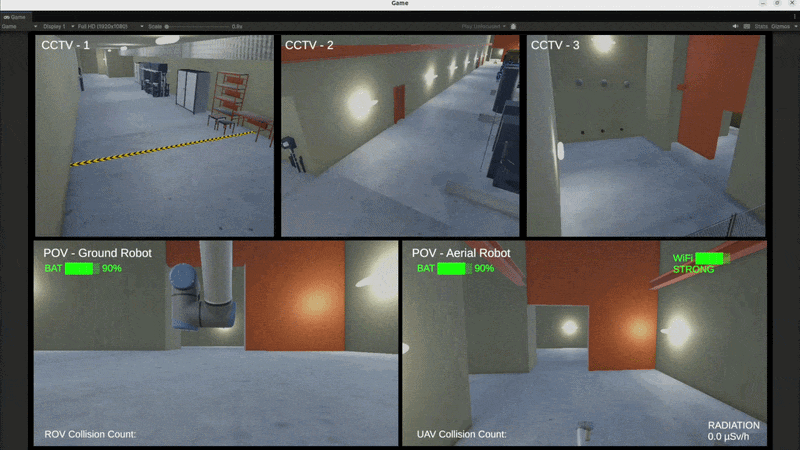
Collaborative control of multiple robots by multiple operators. Developing interaction strategies for coordinated teleoperation where workload, awareness and communication are critical.
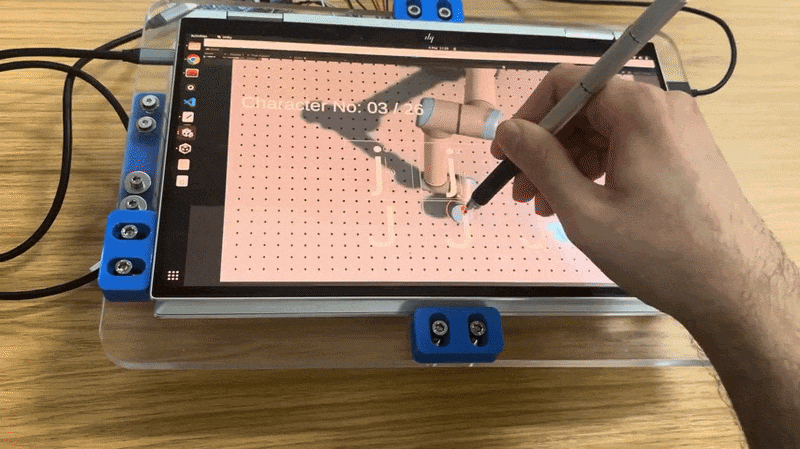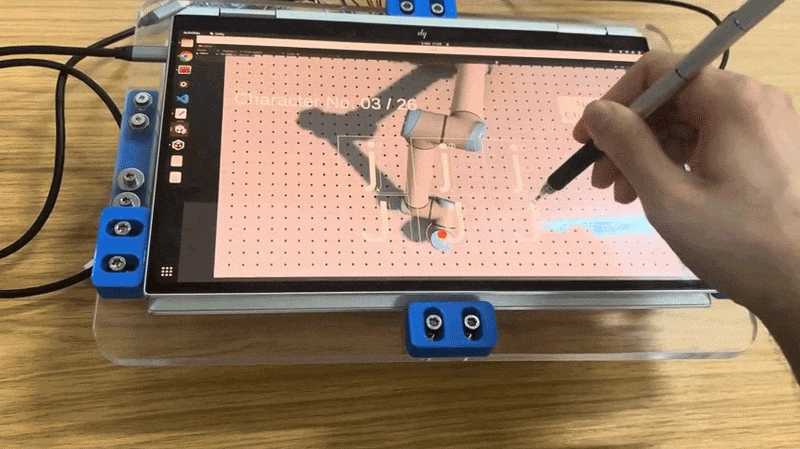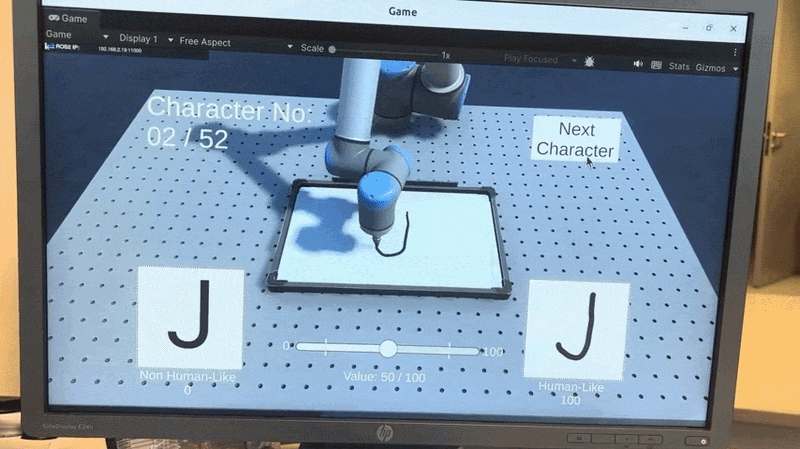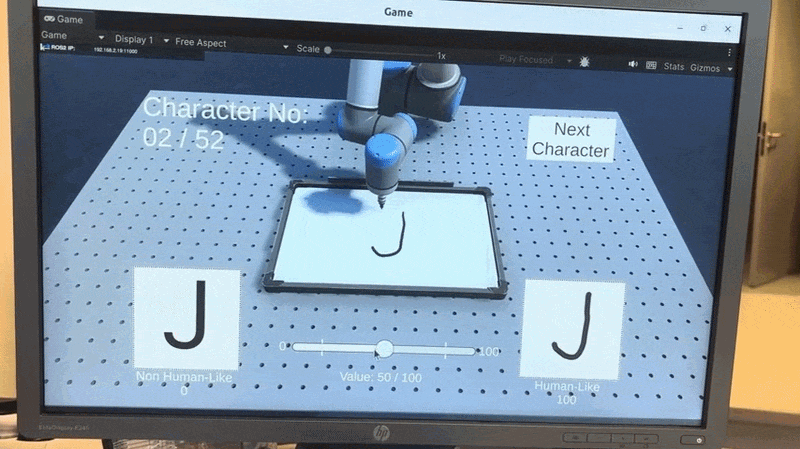
Learning handwritten trajectories from human demonstrations. A dataset and learning pipeline combining position, force and timing, with evaluation of human-likeness in generated robot motion.
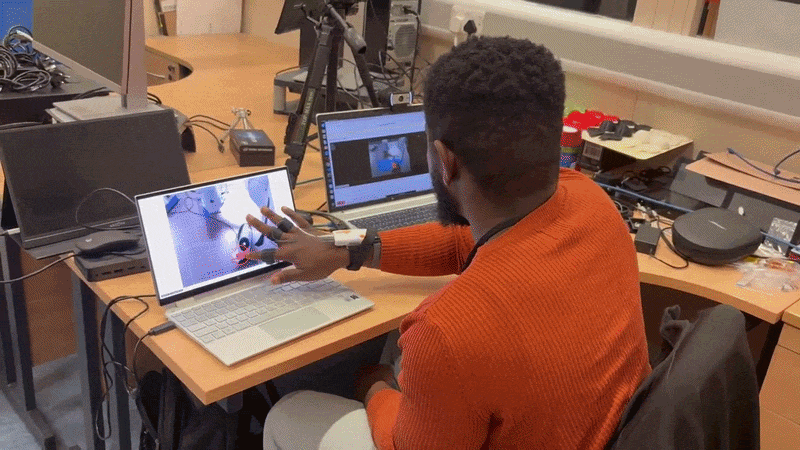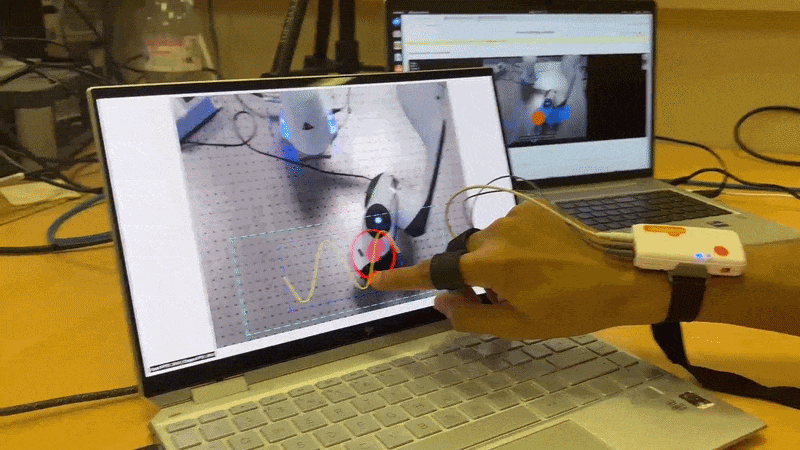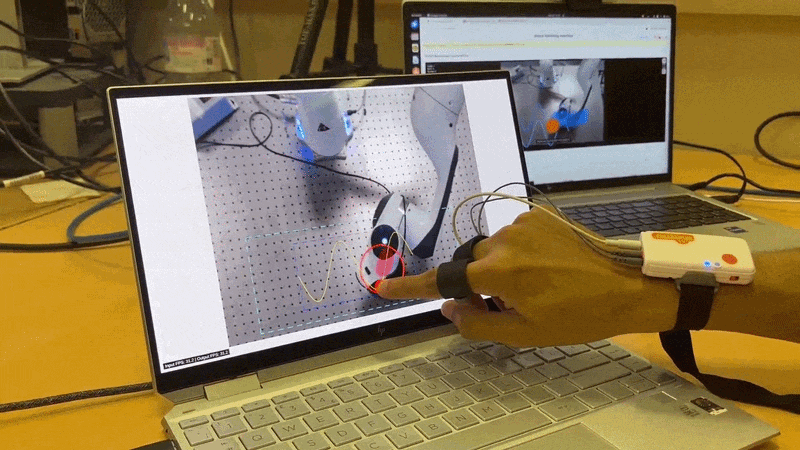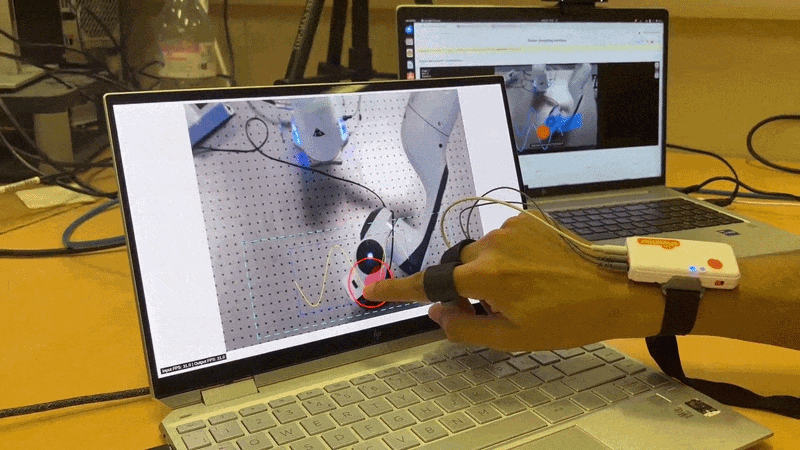
Designing and evaluating touchscreen-based robot teleoperation. Investigating intuitive interaction techniques for robotic manipulation through user-centred design and human-participant evaluation.
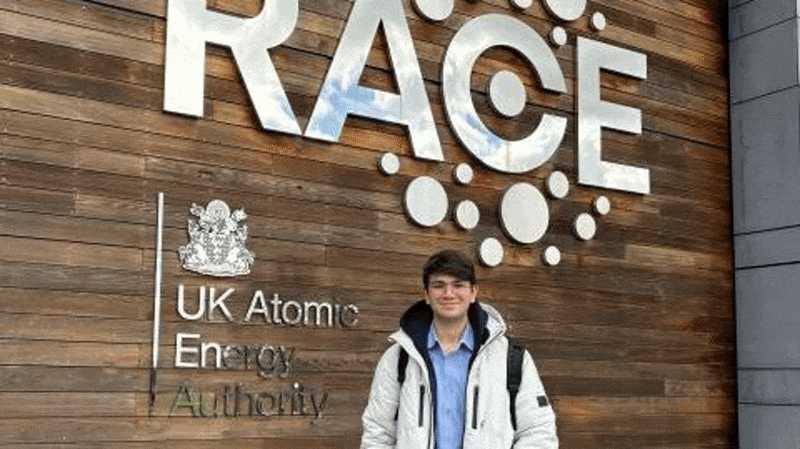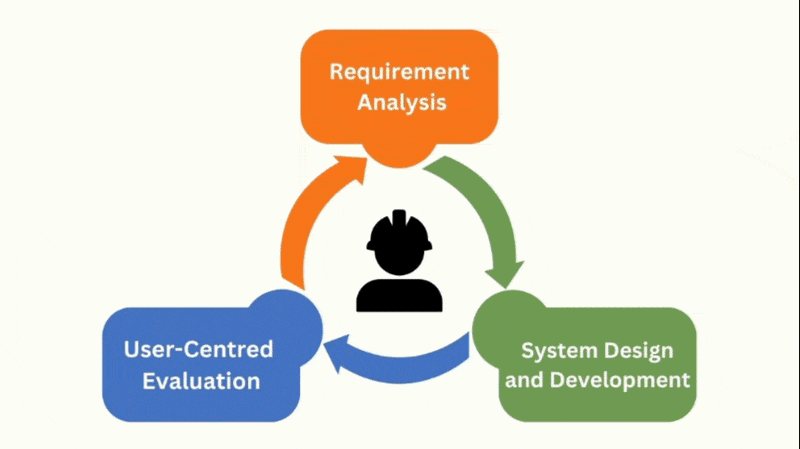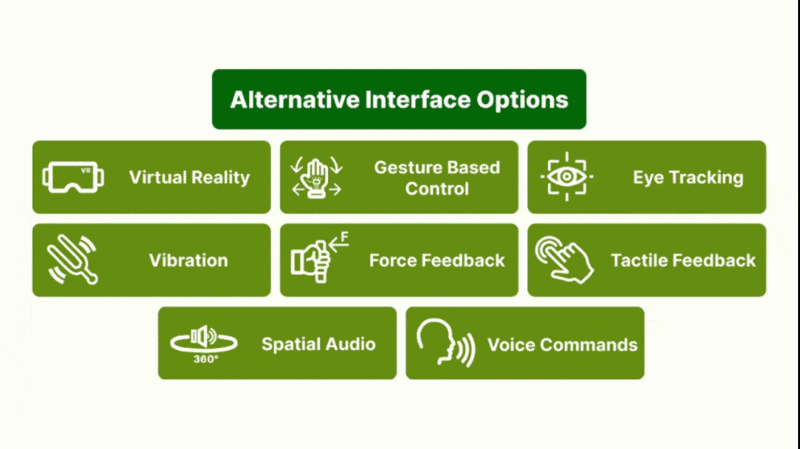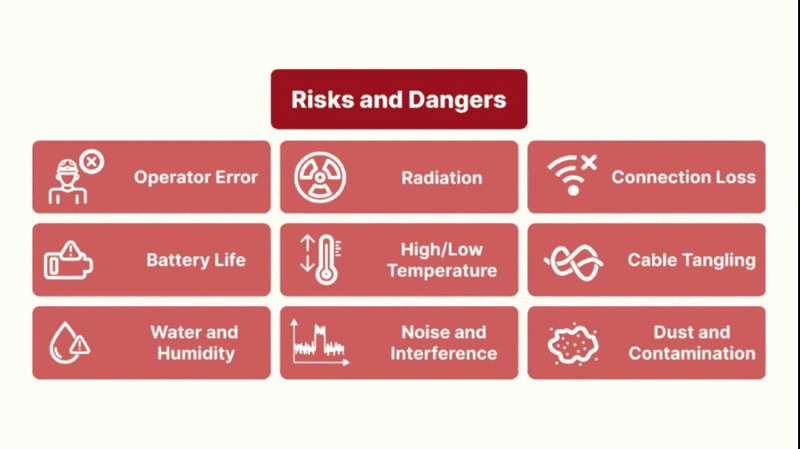
Human-centred teleoperation for hazardous environments. Working with end users and industry stakeholders to identify requirements around workload, situational awareness and safe interaction.
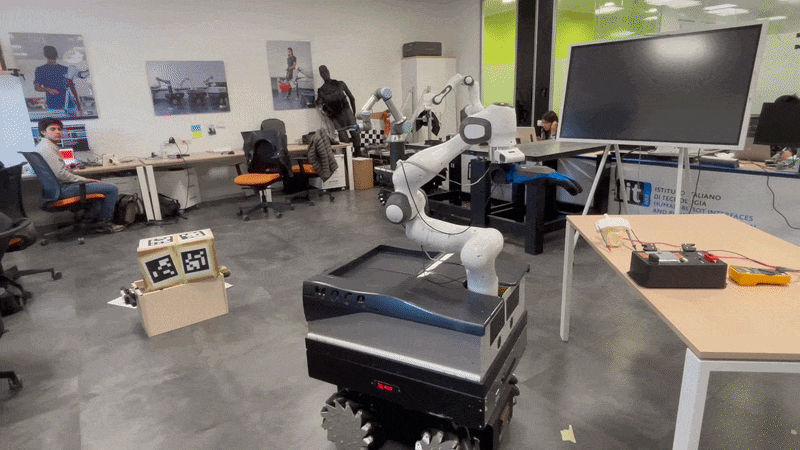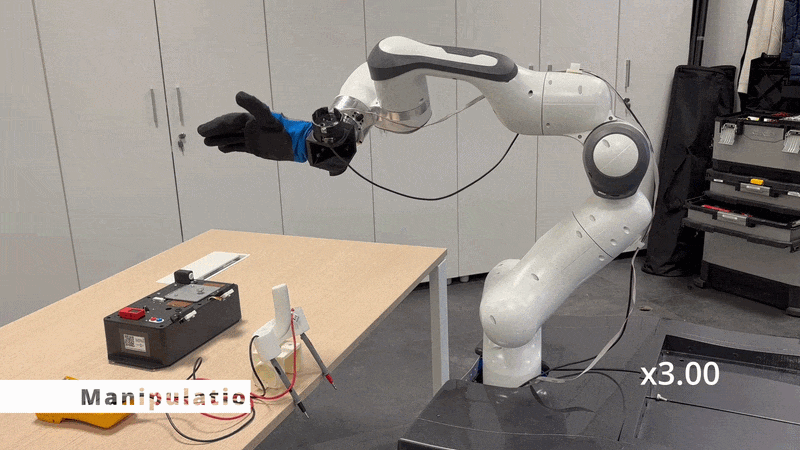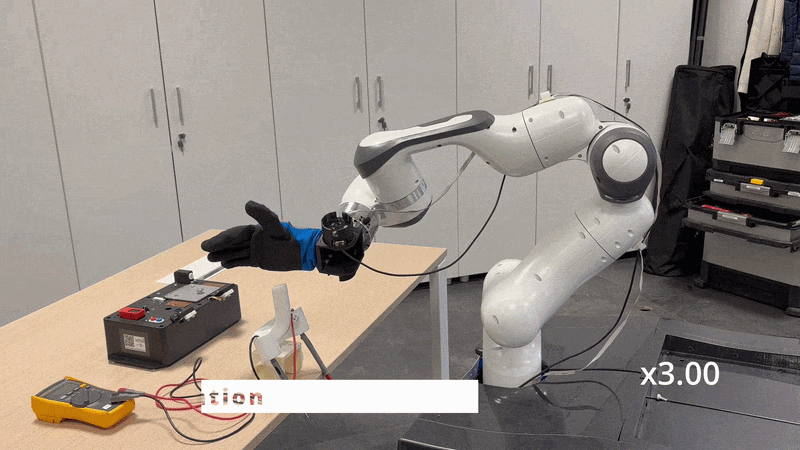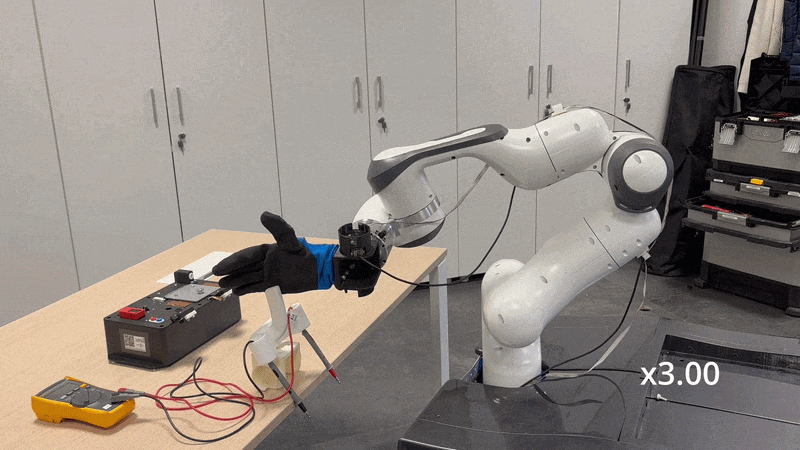
Robotics research across a European doctoral network. Research sprints, field demonstrations and collaborative robotics research across academia and industry.
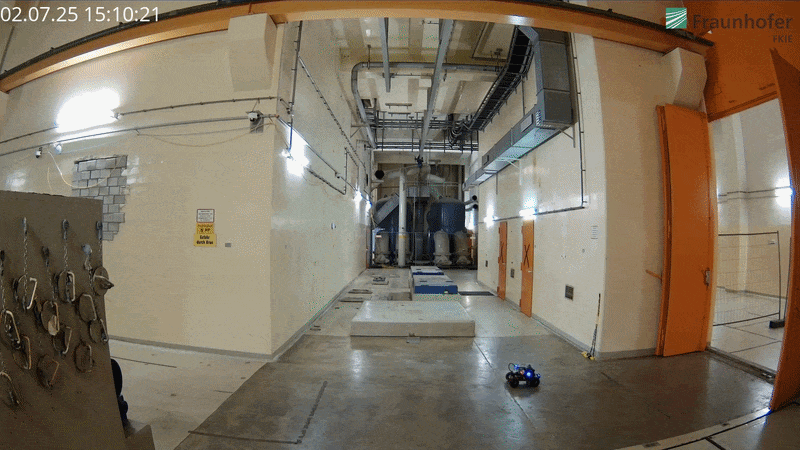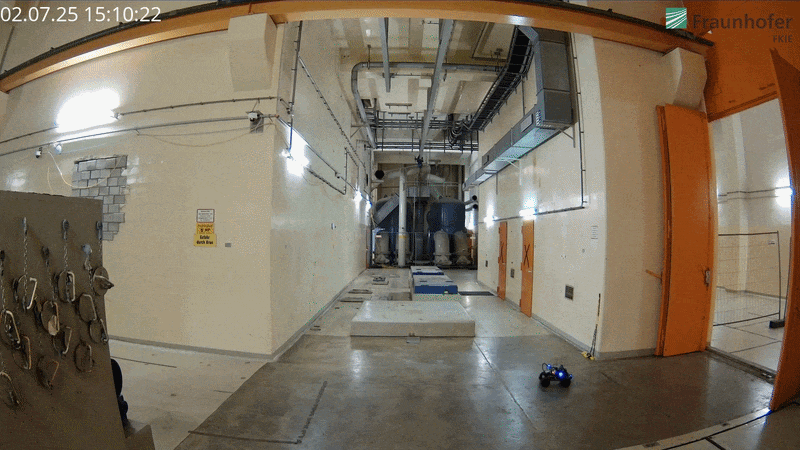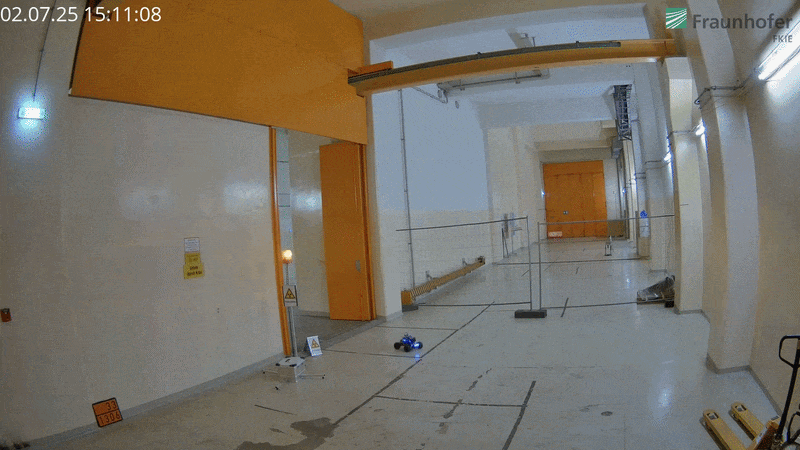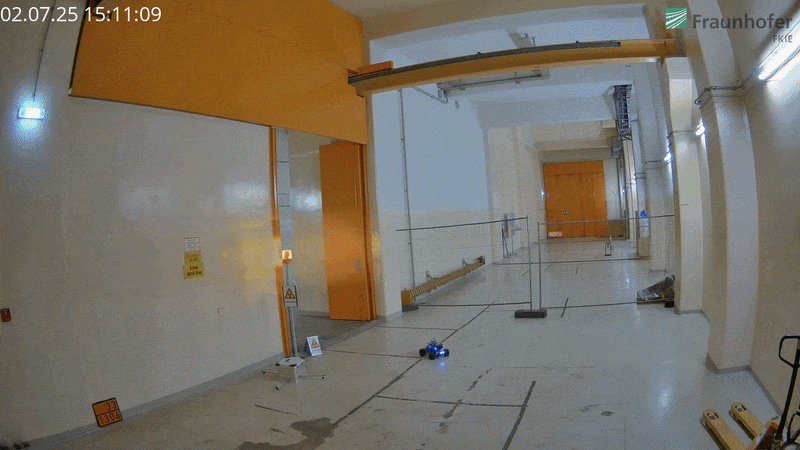
Rapid-development robotic systems for nuclear inspection. Contributing to low-cost air-ground robotic solutions for inspection tasks in nuclear power plant environments.
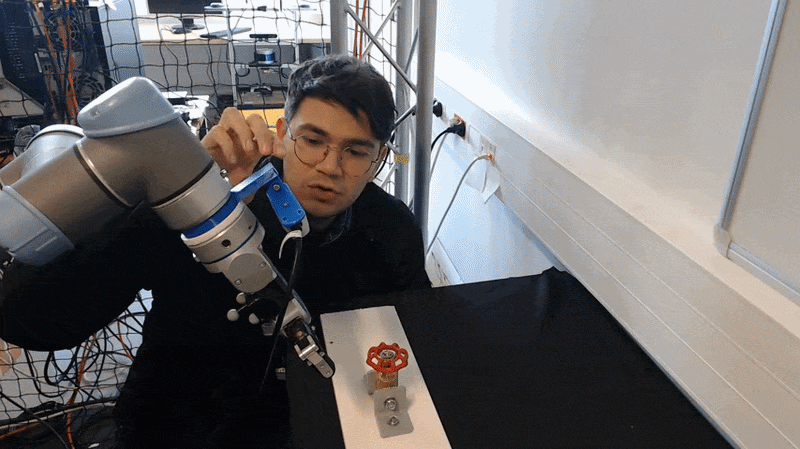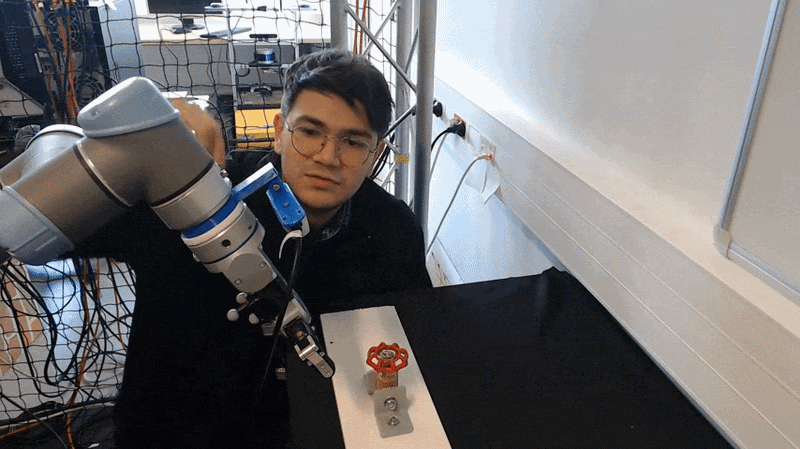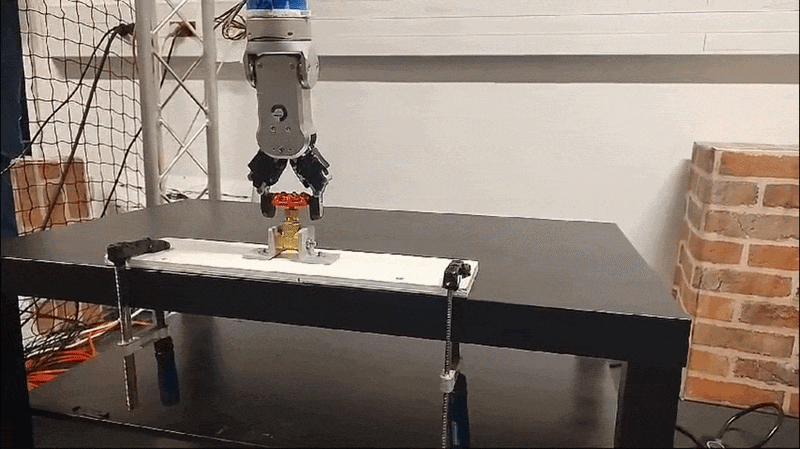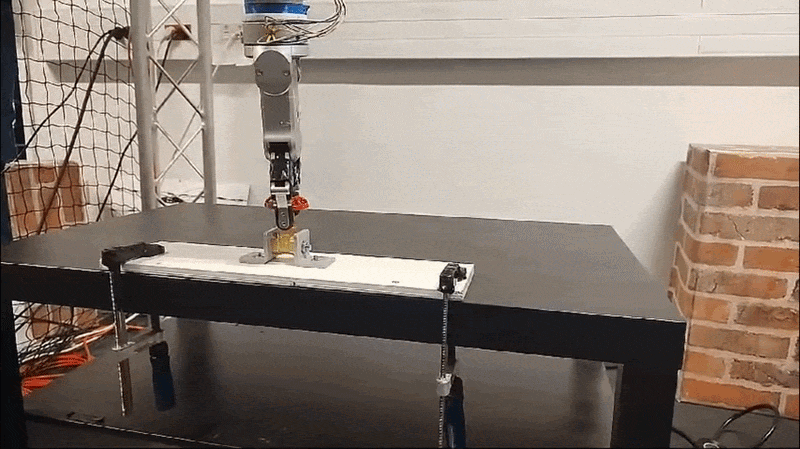
From user requirements to deployable robotic interfaces. Combining interaction design, tactile feedback, robot learning and control to make complex robotic systems more intuitive for human operators.
IEEE ICDL 2026 · arXiv
IEEE RO-MAN 2026 · arXiv
IEEE Telepresence 2026 · Zenodo
IEEE Telepresence 2026 · Zenodo
Robotics and Autonomous Systems · DOI
IEEE/RSJ IROS 2025 · DOI
TAROS 2025, Springer LNCS · DOI
IEEE SSRR 2025 · DOI
Academic training and research roles across robotics, haptics and human-robot interaction.
Marie Skłodowska-Curie Actions Doctoral Fellow within the RAICAM Horizon Europe Doctoral Network.
Thesis Title: User-Centred Design of Robot Teleoperation Interfaces for Nuclear Environments: Swab Sampling and Multi-Operator Multi-Robot Systems
Research in human-centred robotics and teleoperation.
Research in robot interfaces, haptics and hazardous-environment teleoperation.
International research secondments and collaborative robotics work.
Haptic Interface Technology Lab.
Horizon Europe 2023–2026
Doctoral fellowship supporting research in robotics, artificial intelligence and human-centred systems across a European academic and industrial network.
RAICAM project website →| Programming | Python · C++ · C# · MATLAB |
| Robotics | ROS 2 · ROS 1 · Docker · Franka manipulators |
| Control | Simulink · Simulink Real-Time · Beckhoff TwinCAT |
| Haptics | Electrovibration · Tactile feedback · Human-in-the-loop systems |
| Simulation | Digital twins · Gazebo · Isaac Sim |
| Engineering | SolidWorks · Siemens NX · Arduino · Electronics |
Gallery of research visits, demonstrations, conferences, degrees, presentations, outreach and more.